June 2026 – LLM Planning & New Directions
Working on LLM-powered task planning, exploring VLA models, and building a sim benchmark.
Working on LLM-powered task planning, exploring VLA models, and building a sim benchmark.
This blog is a place for concise technical notes from my work in AI and robotics. The topics I plan to write about include ROS2 software architecture, reinforcement learning for control, Isaac Gym and Gazebo simulation workflows, multimodal robot data pipelines, and the practical details of connecting LLMs and VLMs to robotic systems. My goal is to keep the writing useful: implementation notes, design decisions, experiments, lessons from hardware integration, and research summaries that can help another engineer reproduce or improve the work.
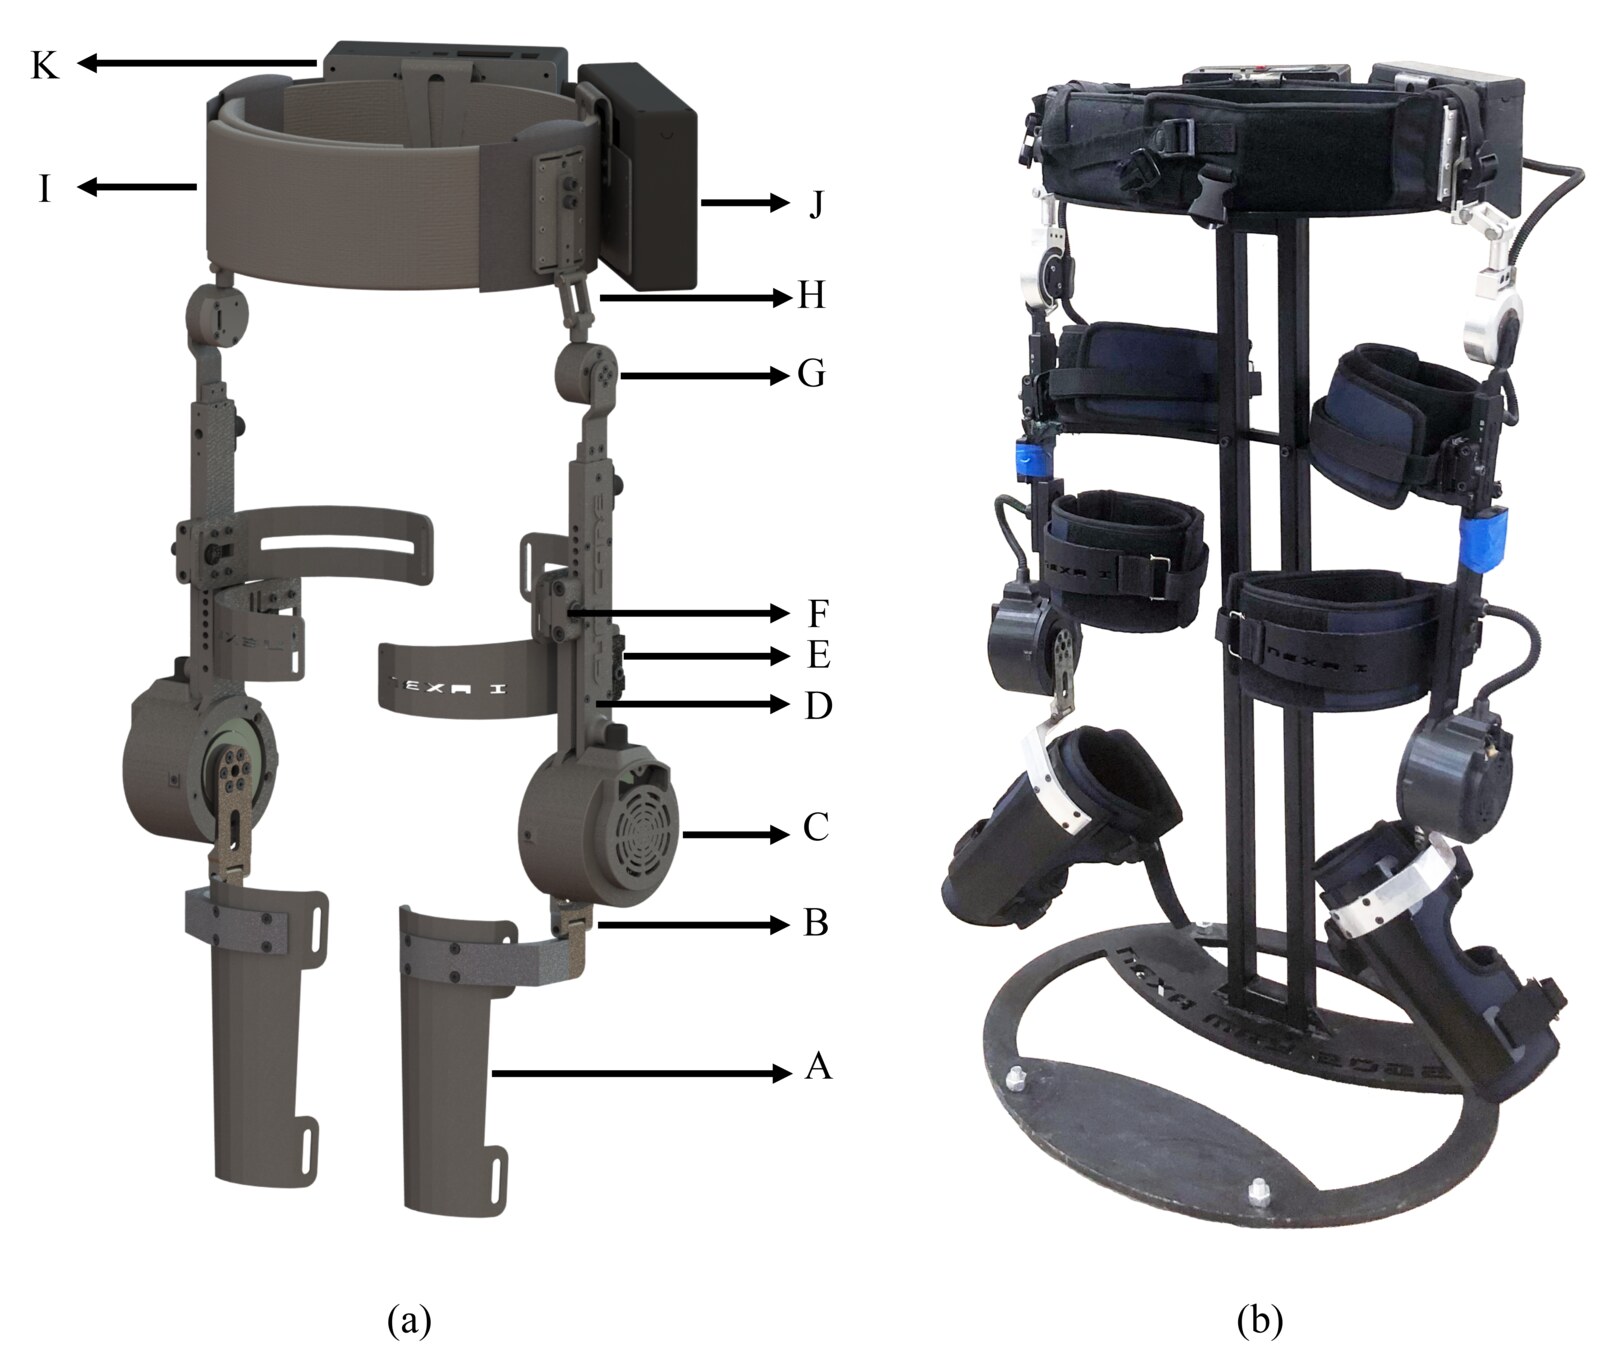
A fuzzy Strength Index adapts knee-exoskeleton torque during sit-to-stand transitions, combining low-power ROS2 software, CAN motor control, and EMG-based engineering evaluation.
A short log entry covering ROS2 simulation updates and system observations.
Robotic task planning using language models and ROS2 execution.