Human Follower Mobile Robot
Vision-based human follower robot built with ROS2 and embedded control.
Vision-based human follower robot built with ROS2 and embedded control.
Robotic task planning using language models and ROS2 execution.
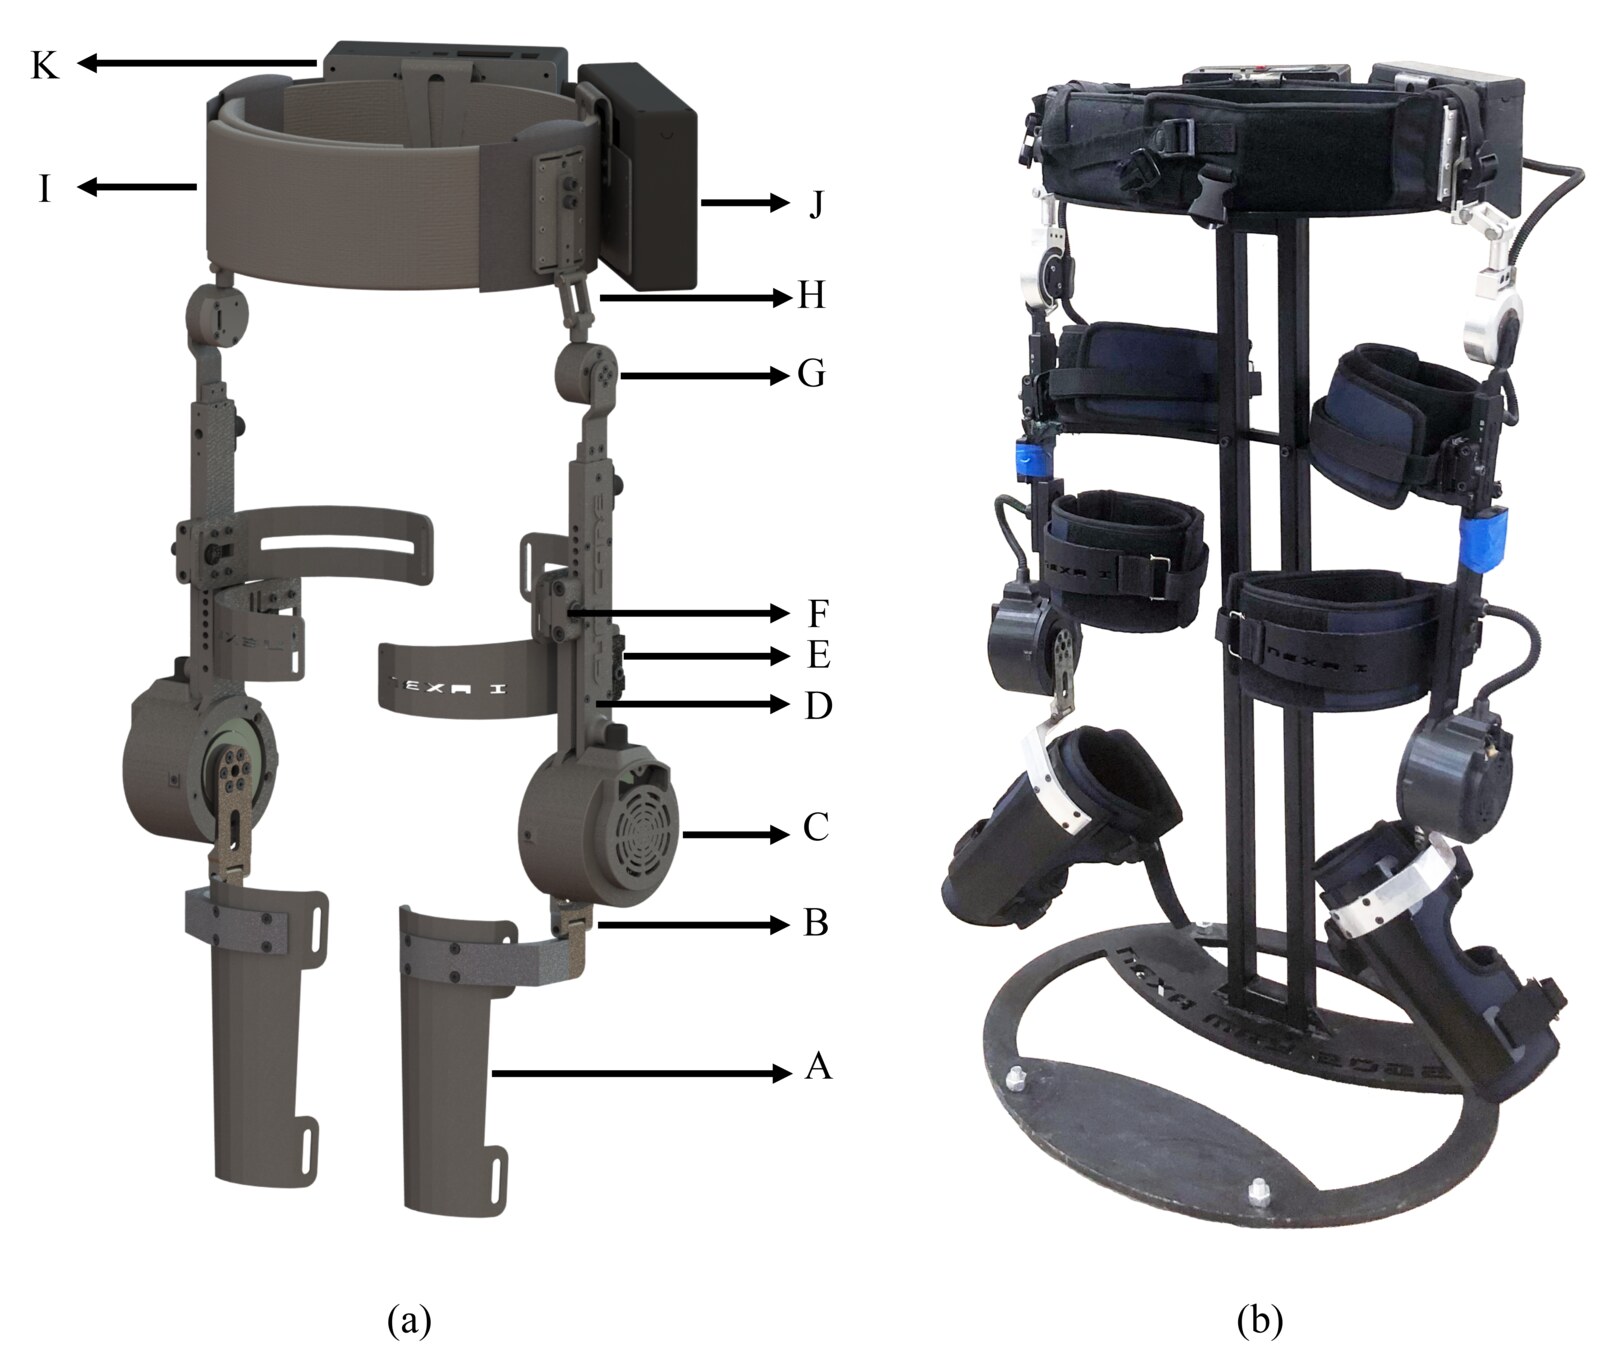
A fuzzy Strength Index adapts knee-exoskeleton torque during sit-to-stand transitions, combining low-power ROS2 software, CAN motor control, and EMG-based engineering evaluation.